Automated warehouses increasingly depend on AGVs and AMRs to move pallets, totes, components, and finished products between storage, picking, production, and shipping areas. As robot fleets become larger and warehouse traffic becomes more dynamic, collision avoidance is no longer simply a navigation feature. It has become an important part of the overall mobile-robot safety and operational architecture.
For manufacturers, warehouse operators, and system integrators, AGV / AMR / Mobile Robot Cluster LiDAR provides a practical way to improve environmental perception and obstacle detection. But the value of LiDAR goes beyond simply detecting an object. Properly configured, it can help a mobile robot recognize changing traffic conditions, create different detection zones, trigger different responses, and coordinate sensing with the robot's control system.
1. Why Collision Avoidance Becomes More Difficult as Warehouses Automate
A traditional warehouse may have relatively predictable vehicle traffic. An automated warehouse can contain dozens or hundreds of moving assets operating simultaneously.
An AGV may encounter:
A worker crossing its route
Another AGV approaching an intersection
An AMR stopped temporarily in an aisle
A pallet extending beyond its expected position
A forklift entering a shared traffic area
Packaging material or other unexpected obstacles
AMRs create an additional challenge because their routes can change dynamically according to warehouse conditions and task assignments.
This means collision avoidance cannot depend entirely on a predefined route. The robot needs continuous environmental information.
This is where LiDAR becomes valuable: it provides distance information about objects within the sensor's scanning field, allowing the mobile robot or its control system to respond to changes in its surroundings.
2. How LiDAR Detects Obstacles Around an AGV or AMR
An industrial laser scanner such as MILS-F30 uses a time-of-flight measurement principle. The sensor emits laser pulses, receives their reflections, and calculates distance from the measured travel time of the light.
MILS-F30 provides a 270° scanning angle, a default angular resolution of 0.25°, and a maximum detection distance of 50 m. Its documented detection distance at 10% reflectivity is 20 m, with measurement accuracy of approximately ±2 cm under specified conditions.
For an AGV or AMR, this means the sensor can continuously build a distance-based picture of the surrounding environment within its scanning plane.
Instead of relying only on fixed physical barriers, the robot can use this information to recognize whether its path is clear or whether an obstacle has entered a predefined detection area.
3. From Simple Detection to Intelligent Collision Avoidance
Simply detecting an obstacle is not enough.
A commercially useful collision-avoidance system needs to determine what action should happen after detection.
For example:
Obstacle detected → detection zone identified → robot status evaluated → control response triggered
Depending on the application, the response may include:
Maintaining normal speed
Issuing an obstacle warning
Reducing speed
Changing the navigation path
Temporarily stopping
Triggering a higher-level safety function
The exact response should be determined by the robot's control and safety architecture.
This approach allows LiDAR to become part of a broader mobile-robot control strategy instead of functioning as an isolated distance sensor.
4. Multi-Zone LiDAR Makes Warehouse Traffic More Flexible
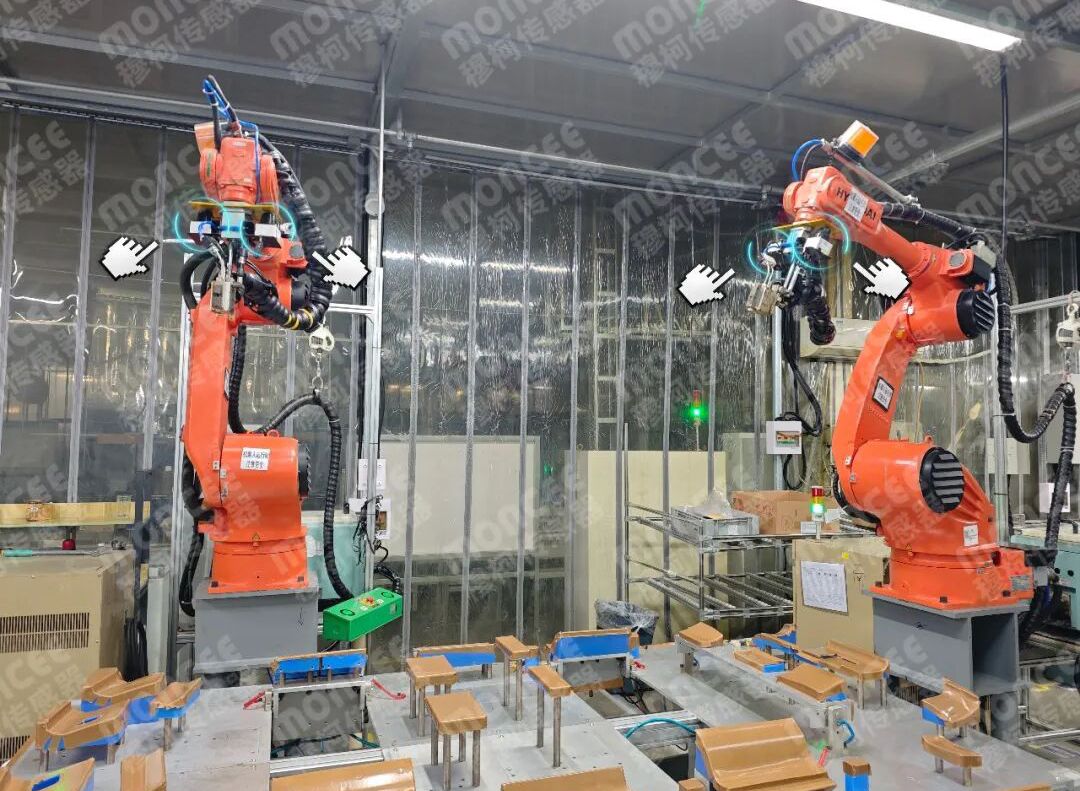
One of the most useful features for AGV and AMR applications is configurable detection zones.
MILS-F30 supports 16 area groups, with each group containing three configurable areas. Four digital inputs can be used to switch between area groups.
The three areas can be configured as:
Outer area
Middle area
Inner area
The sensor supports rectangular, sector, and polygonal detection areas.
This allows engineers to create different detection strategies for different warehouse scenarios.
For example, a robot traveling through a wide open aisle may use a relatively long detection area. When approaching a narrow turning point, loading station, or pedestrian interaction area, the system can switch to another configured area group.
This is particularly valuable for Mobile Robot Cluster LiDAR deployments because different robots, routes, speeds, and operating zones may require different detection configurations.
5. Detection Response Must Be Connected to Robot Dynamics
A LiDAR's detection capability cannot be evaluated independently from the robot's stopping performance.
Suppose an AMR is traveling at high speed while carrying a heavy load. Detecting an obstacle is only the first step. The system must have enough time for:
Detection → processing → communication → control decision → drive response → braking
The MILS-F30 documentation specifies an approximately 66 ms area-detection initial response parameter. However, this should not be interpreted as the complete AGV stopping time.
Actual stopping performance depends on the complete system, including vehicle speed, load, controller response, drive system, braking characteristics, and floor conditions.
For commercial warehouse projects, engineers should therefore evaluate the entire detection-to-stop chain rather than selecting a sensor solely because it has a fast response specification.
6. Environmental Conditions Can Affect Collision Detection
Automated warehouses are not controlled laboratories.
LiDAR may encounter:
Dark objects
Highly reflective metal surfaces
Transparent materials
Dust
Strong lighting
Changing temperatures
Moving people
Pallets with irregular shapes
MILS-F30 is documented with IP65 protection, an operating temperature range of approximately −25°C to +55°C, ambient-light resistance up to 80,000 lux, and a 905 nm Class 1 laser.
These specifications provide useful reference points when evaluating the sensor for industrial warehouse environments.
However, the actual installation should always be tested against the customer's specific floor layout, target materials, lighting, dust conditions, and robot operating requirements.
7. LiDAR Communication Determines How Easily It Integrates into the Robot
A LiDAR sensor is only commercially useful when it can communicate effectively with the robot's control architecture.
MILS-F30 supports Ethernet and Type-C interfaces for configuration and data communication, with active and passive data transmission modes available.
For an AGV or AMR manufacturer, integration should consider:
Controller compatibility
Communication protocol
I/O architecture
Data transmission method
Configuration software
Diagnostics
Maintenance requirements
These factors directly affect engineering development time and the total cost of an OEM project.
8. Fleet-Level Configuration Is a Commercial Advantage
When one warehouse uses only a single mobile robot, configuration efficiency may not seem particularly important.
When the customer operates a fleet, it becomes a major procurement consideration.
MILS-F30 supports importing and exporting area configurations, making it possible to replicate established detection-area settings across devices.
For OEM manufacturers and system integrators, this can reduce repetitive commissioning work and improve configuration consistency across a robot fleet.
Therefore, the commercial value of AGV / AMR / Mobile Robot Cluster LiDAR should be evaluated not only by unit price, but also by:
Installation time
Commissioning efficiency
Configuration management
Technical support
Replacement convenience
Customization capability
Long-term supply stability
9. Safety LiDAR and Navigation LiDAR Must Be Clearly Distinguished
One important issue should not be overlooked: industrial navigation/obstacle-avoidance LiDAR is not automatically a certified safety laser scanner.
MILS-F30 is documented as an industrial laser scanning sensor for navigation, obstacle avoidance, and area detection. Its documentation does not establish IEC 61496 safety certification, SIL classification, or PL classification.
For applications where the LiDAR output is intended to perform a formal personnel-protection safety function, the required safety-certified device and complete safety architecture must be separately verified.
This distinction is particularly important when an OEM or system integrator is preparing documentation for a customer's safety assessment.
Current industry guidance also emphasizes separating navigation/obstacle-avoidance sensing from the certified protective-stop function where the latter is required.
10. Why LiDAR Matters for Commercial Warehouse Automation
The business value of LiDAR is ultimately connected to operational reliability.
A well-designed detection system can help support:
More flexible AGV/AMR traffic
Reduced collision risk
Better obstacle awareness
More adaptable robot routes
Standardized fleet configurations
Easier OEM integration
Scalable deployment across multiple robots
For warehouse operators, this can translate into a more structured approach to automation expansion. For robot manufacturers, it can simplify the development of standardized sensing platforms. For system integrators, configurable LiDAR can provide greater flexibility when adapting one sensor platform to multiple customer projects.
Conclusion
AGV / AMR / Mobile Robot Cluster LiDAR is becoming an important component of automated-warehouse perception and collision-avoidance systems.
Its role is not simply to determine whether an object is nearby. With configurable detection zones, wide-area scanning, industrial communication interfaces, and fleet-oriented configuration capabilities, LiDAR can become part of a broader strategy for managing dynamic robot traffic.
MILS-F30, with its 270° scanning coverage, up to 50 m maximum detection distance, configurable multi-area detection, Ethernet/Type-C communication, and industrial environmental specifications, provides a strong technical basis for navigation, obstacle avoidance, and area-detection applications.
For commercial AGV and AMR projects, however, successful deployment depends on more than the sensor itself. Engineers must consider robot dynamics, stopping performance, installation conditions, communication architecture, fleet management, and—where required—the use of separately certified safety components.
The most effective LiDAR solution is therefore not simply the one with the longest range. It is the one that can be reliably integrated, efficiently deployed, commercially scaled, and correctly matched to the robot's actual operating environment.


 English
 简体中文
 Indonesian
 Previous:
 Back to list


